Match the detection job to the treatment
Vision-guided weed control links an observed plant with a treatment action. A system may detect green vegetation on a background, discriminate crop from weeds, or identify plant positions for mechanical hoeing. Those tasks are different. A detector suitable for fallow ground is not automatically suitable for separating weeds from a green crop canopy.
Specify crop, growth stage, row layout and intended treatment before choosing hardware. Camera-guided spot spraying, optical vegetation detection and mechanical intra-row weeding belong in separate comparison groups. The systems below are tractor or sprayer implements and retrofit sensing packages. They should not be described as autonomous vehicles simply because their treatment decisions are automated.
Detection is only the start of the measurement chain
Cameras collect observations that software classifies or relates to expected plant positions. Controlled lighting and covers can reduce the variation in what the camera sees. The controller then combines target location with travel speed, camera-to-tool offset and actuation delay. A correctly detected weed can still miss treatment if the tool reaches it at the wrong time.
A false positive is an object incorrectly selected for treatment. A false negative is a target missed by the detection system. For crop-selective work, evaluate both crop injury and surviving weeds. Report the crop and weed stages tested, lighting, dust, residue and canopy cover. Chemical reduction by itself does not establish equivalent weed control.
Five sensing and treatment systems
ARA, Greeneye and SymphonyVision Spot use vision to direct spraying in supported applications. WeedSeeker 2 is an optical spot-spraying approach whose suitability depends on the operating configuration. IC-Weeder AI acts mechanically between and within crop rows. Compare crop-model availability and treatment mechanism before comparing boom width or throughput.
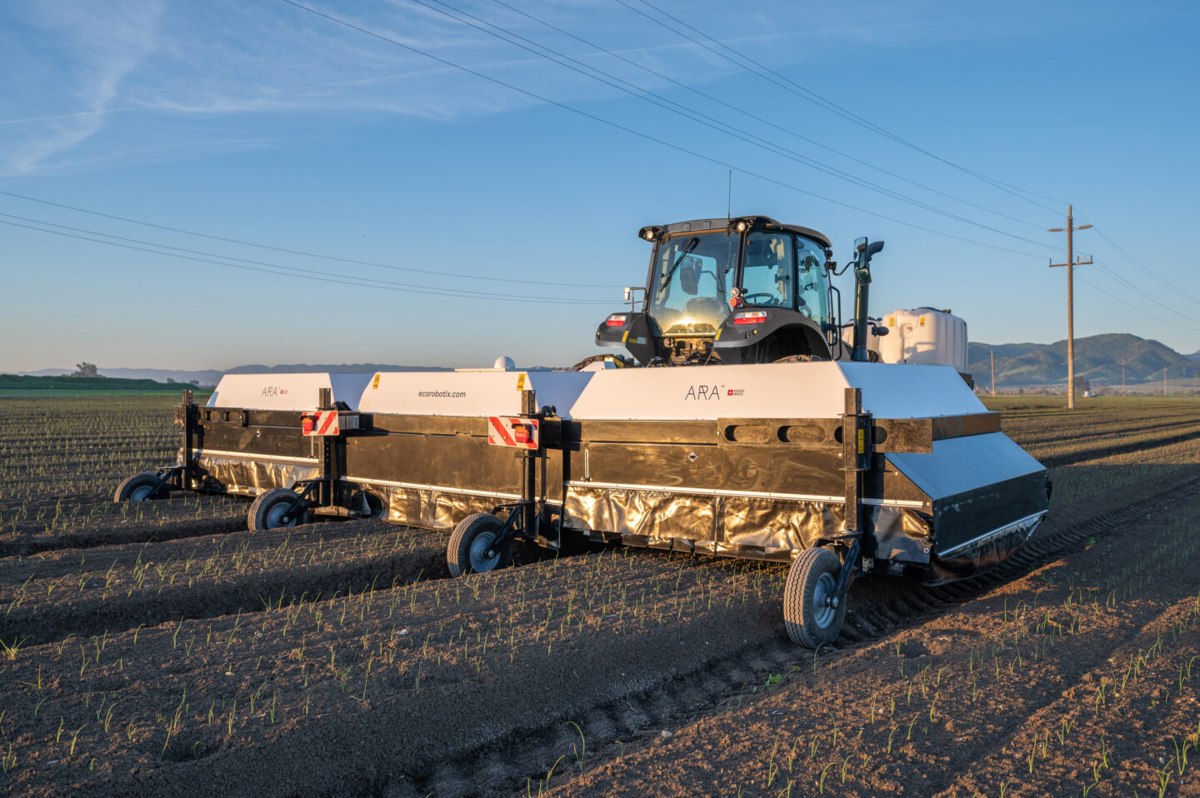
Six-metre crop-care spraying configuration
Ecorobotix ARA
A camera-guided sprayer that positions small treatment areas around detected plants. Its selective performance depends on crop models, field conditions and complete installation.
Check crop/weed stage, tractor requirements, treatment mode and current configuration.
View product details ↗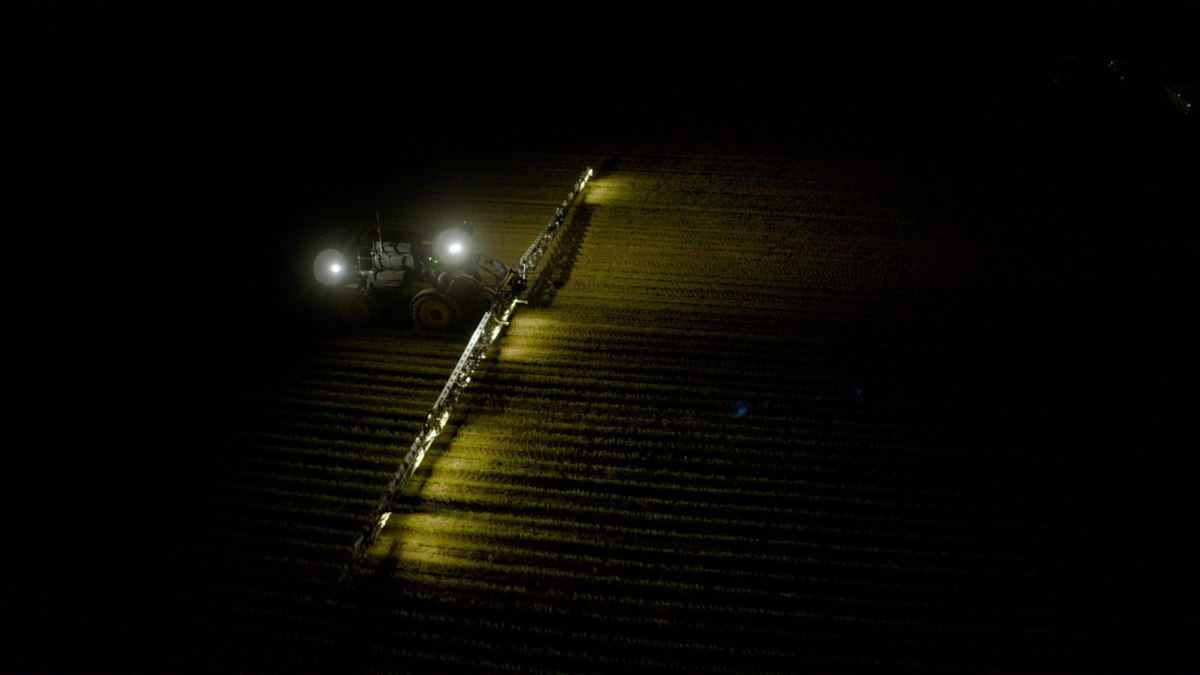
Supported sprayer retrofit system
Greeneye Precision Spraying
A retrofit precision-spraying architecture using boom-mounted cameras and treatment control. Verify the actual crop and machine combination rather than applying general savings examples.
Confirm crop support, boom configuration and service/data package locally.
View product details ↗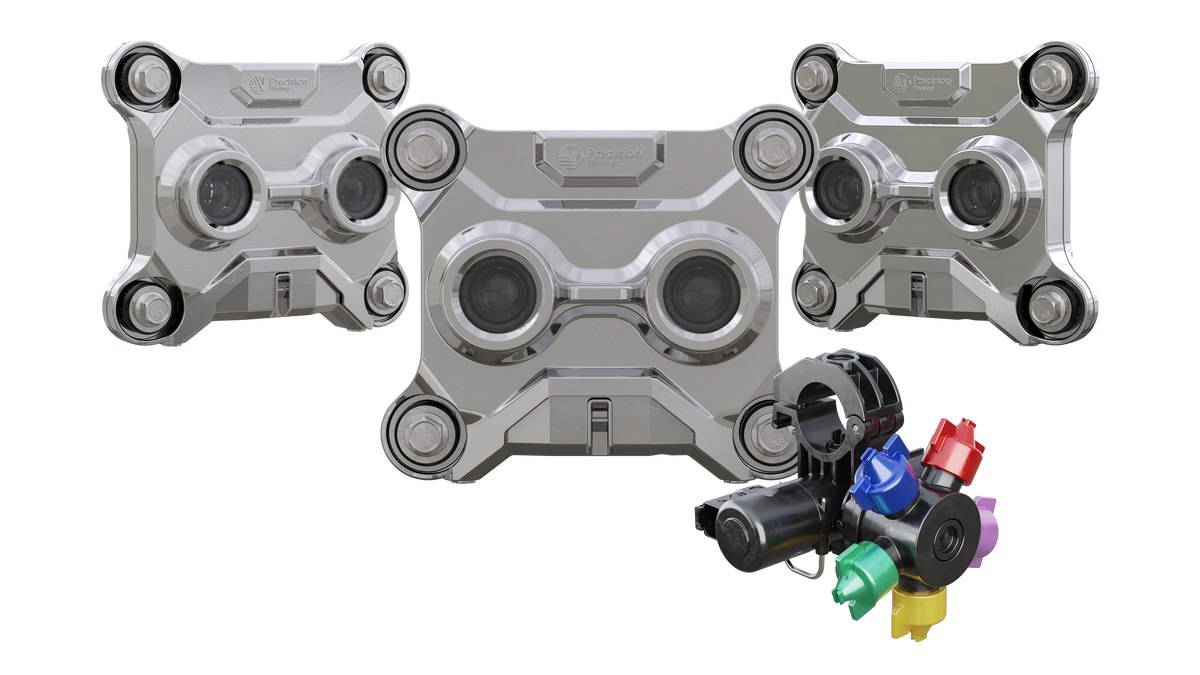
Spot mode; matched SymphonyNozzle and 20|20
Precision Planting SymphonyVision Spot
A vision-based system that varies application and switches nozzles according to detected weeds. The complete package includes treatment hardware, cameras and a compatible control installation.
Verify current software and required pump hardware; Panorama scouting is a separate service.
View product details ↗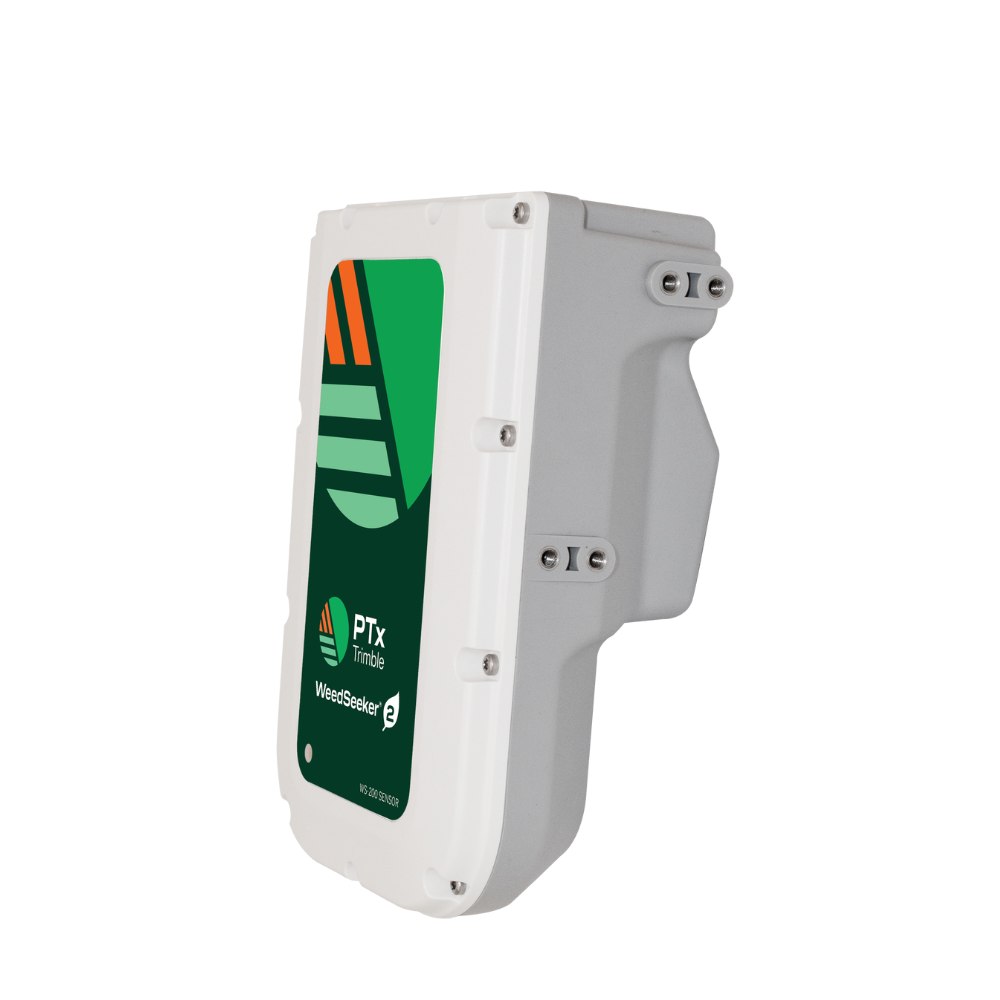
Optical spot-spray sensor system
PTx Trimble WeedSeeker 2
An optical spot-spraying approach available for different installation contexts. Assess the crop/background task and nozzle arrangement before comparing it with camera-classification systems.
Do not assume crop/weed discrimination for every installation; verify the operating configuration.
View product details ↗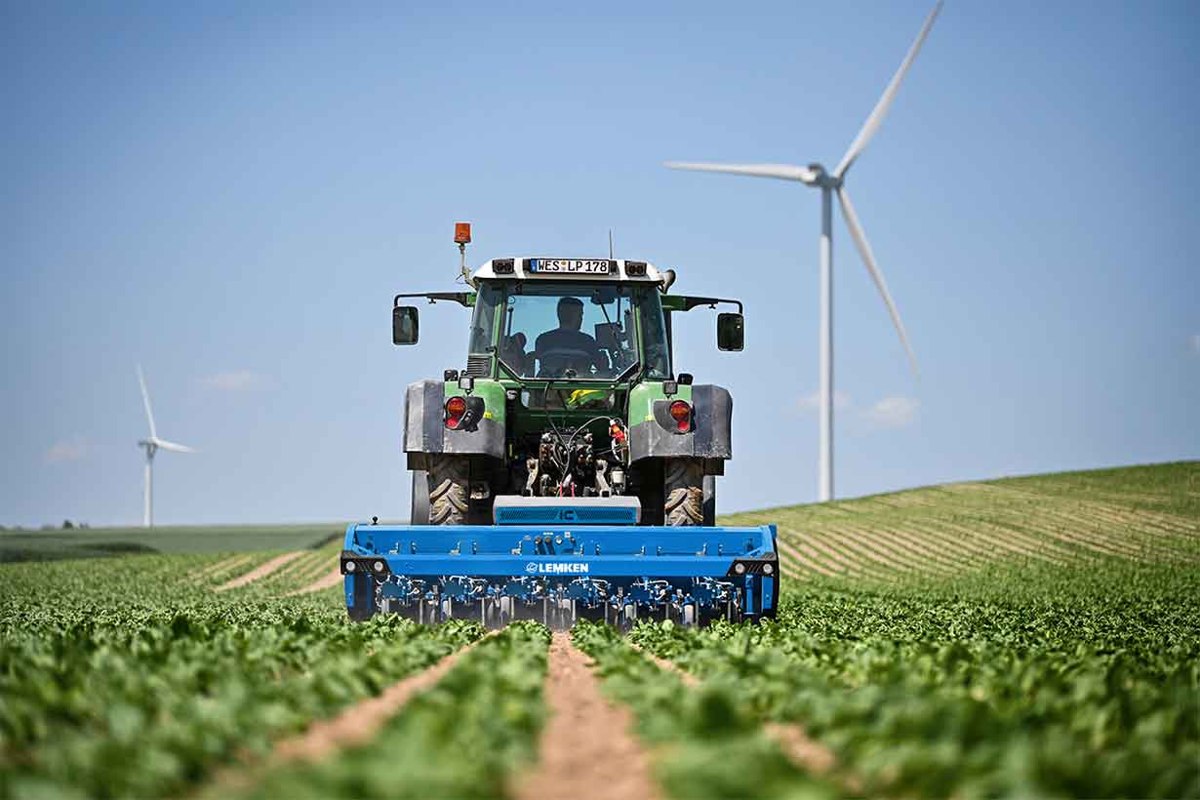
Camera-guided mechanical intra-row hoe
LEMKEN IC-Weeder AI
A mechanical hoe that links plant recognition to intra-row sickle knives and lateral guidance. It is a treatment alternative to spraying, with different agronomic and machine requirements.
Soil condition, plant spacing and depth settings constrain the operation.
View product details ↗| Model | Measurement / role | Data connection | Coverage / installation |
|---|---|---|---|
| Ecorobotix ARA | Plant-by-plant camera detection and targeted spraying | Supplied tablet and integrated treatment control | Tractor-mounted spraying system with front tank |
| Greeneye Precision Spraying | Camera-based target detection and treatment | Integrated detection, nozzle control and scouting workflow | Matched sprayer boom and retrofit configuration |
| Precision Planting SymphonyVision Spot | Weed severity detection with variable-rate spot spraying | Gen 3 20|20, cameras, SymphonyNozzle; pump compatibility matters | Supported sprayer boom and current crop configuration |
| PTx Trimble WeedSeeker 2 | Vegetation detection and targeted nozzle control | Sensors with compatible control and spraying equipment | Configured sprayer, orchard or vineyard installation |
| LEMKEN IC-Weeder AI | Crop detection, row positioning and blade actuation | Cameras, job computer, hydraulic shift and pneumatic knives | Supported row/plant spacing and mechanical tool configuration |
What to verify on the actual machine
Check mounting height, camera angle, viewing area and camera-to-nozzle or camera-to-knife distance. A boom that flexes, rolls or changes height affects where a detected target reaches the treatment area. Measure and configure the installation as a system, including speed input, hydraulic or electrical capacity and the treatment hardware.
For spraying, confirm nozzle response, flow, pressure and the permitted application-rate range. The SymphonyVision operator guide identifies required hardware and pump arrangements; verify the current software and regional support before ordering. For mechanical hoeing, row and plant spacing, soil condition and depth settings determine whether blades can move safely around the crop.
Test detection and treatment together
Evaluate marked field strips containing the weeds and crop stages that matter on your farm. Inspect treated and untreated patches after an appropriate interval for the chosen method. Record misses, crop injury and the actual area treated. Repeat under conditions that challenge the installation, such as shadows, crop residue or uneven ground.
Travel speed turns time delay into distance. At 8 kilometres per hour, a 0.1 second delay corresponds to about 0.22 metres of movement. Even short timing differences can matter when the intended treatment footprint is small.
Read crop support more carefully than savings claims
Ask which crop algorithms, weed targets and treatment modes are available in the quoted region and software version. Request a demonstration in your crop, not only a clean display of individual plants. Check how the system handles uncertain classification, dense canopy, damaged cameras and lost speed data. A machine’s supported use can be narrower than its marketing examples.
Compare total hardware, installation, licences, data services, replacement cameras and local support. For a mechanical tool, include suitable tractors, hydraulic supply and setup labour. For a spray system, keep treatment effectiveness and local product-label requirements in the decision alongside the volume saved.
A shift toward individual plant treatment
LEMKEN identifies IC-Weeder AI with the FARM MACHINE 2022 mechanical weed-control award. Precision Planting’s current documentation includes 2026 SymphonyVision software requirements. These dated records show the move toward plant-level detection and updated control software without implying that every crop or season is supported by every system.
Detection and actuation terminology
- Green-on-green
- Distinguishing target vegetation from a living crop background.
- Inference
- Applying a trained model to an observation to make a detection or classification.
- Actuation latency
- Time between a treatment command and the physical action.
- Occlusion
- A target being partly or entirely hidden by another object.
Does a camera-guided sprayer remove the need for scouting?
No. Detection records can support scouting, but blind spots, unsupported targets and treatment escapes still need field inspection. Check the areas a camera cannot see and verify the effect of the treatment. A useful dataset describes what was detected and applied rather than implying that everything in the field was observed.
Sources & further reading
- ARA Field Sprayer - Ecorobotix
- Greeneye Technology™ - Technology
- SymphonyVision | Spot | Precision Planting | Upgrade Your Farm Equipment
- WeedSeeker 2 | Products | PTx Trimble
- IC-Weeder AI – Smart Intra-Row Weeding Solution | LEMKEN
- Precision Planting SymphonyVision operator guide, current 2026 software scope